

INSPIRA-6G
INSPIRA-6G is a strategic project framed within CDTI Innovación’s INNTERCONECTA-STEP program, aimed at researching and implementing advanced remote inspection, surveillance, and safety solutions for critical infrastructures, industrial environments, and emergency scenarios.
The project addresses operational challenges in hostile or hard-to-access environments, where human tasks involve high risks, by combining autonomous robotics (ground and aerial), distributed Artificial Intelligence (Edge/Cloud), high-precision sensing (LiDAR, stereoscopic vision, multispectral cameras), and Virtual Reality immersive teleoperation environments.
The core technical innovation of INSPIRA-6G lies in the deployment of a multi-domain hybrid connectivity scheme that integrates private/public 5G/6G networks (OpenRAN) with satellite links (Direct-to-Mobile / DTM). Through intelligent cognitive orchestration, adaptive quality of service (QoS/slicing), and Joint Communication and Sensing (JCAS), the system ensures extended perception and continuous, resilient, and safe operation for robotic control and real-time decision-making, even under degraded network conditions or in areas lacking terrestrial infrastructure.
ROBOTNIK AT THE PROJECT
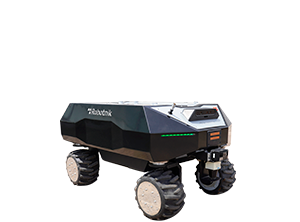
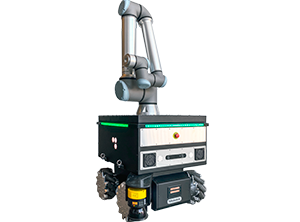
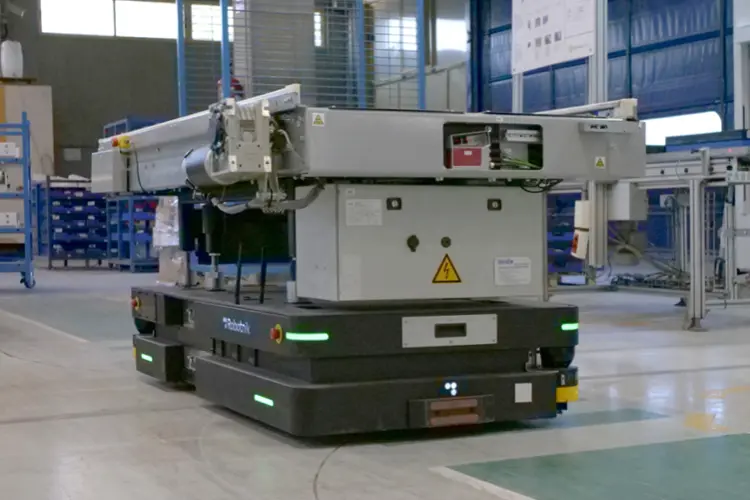
Within the framework of the INSPIRA-6G project, Robotnik leads the design, development, integration, and technical validation of autonomous mobile robotic platforms executing inspection and safety missions in complex environments.
Robotnik’s involvement is structured around the following key technical axes:
- Edge AI: Implementation of embedded AI models on the robotic platform for real-time automatic anomaly detection (identifying unauthorized individuals or vehicles, fire outbreaks, or structural damage) and generating video clips around critical events.
- 3D LiDAR Processing: Researching compression and processing algorithms for high-density 3D LiDAR point clouds to optimize network bandwidth usage and reduce onboard computing overhead.
- Digital Twins and Immersive Teleoperation: Creating and empirically calibrating Digital Twins of mobile robots for mission simulation and pre-validation, defining efficient and interoperable communication protocols for real-time data streaming to Virtual Reality immersive teleoperation stations.
- Experimental Validation: Leading the progressive integration of perception, network, and robotic control modules, as well as experimental testing in laboratory and semi-controlled environments to validate system performance and operational resilience.

Partners in the project


More projects