

SICODI
SICODI is an initiative framed within CDTI Innovación’s INNTERCONECTA program, aimed at driving the industrial transformation toward the Factory 5.0 paradigm by developing an open, modular, and distributed cognitive industrial automation architecture.
The project addresses key challenges in current manufacturing environments, such as the rigidity of centralized SCADA architectures, cybersecurity vulnerabilities, operational latency bottlenecks, lack of resilience, and inefficient energy management, by creating an intelligent and interoperable platform. To achieve this objective, the initiative structures its work plan into five strategic activities spanning from the conceptual design of the cognitive architecture to the integration of connectivity, robotics, digital twin subsystems, and the final prototype validation in a relevant industrial environment (reaching TRL6).
The technical value of SICODI lies in the synergistic integration of deep digital technologies (STEP): hybrid Cloud-Edge-Embedded processing with Federated Learning, advanced private 5G/6G communications based on Open RAN architecture with adaptive slicing, post-quantum cryptography (TLS-PQC), and blockchain-based traceability for the Digital Product Passport (DPP).
This digital infrastructure supports the deployment of collaborative mobile robotics platforms enhanced by Large Language Models (LLMs) and Explainable Artificial Intelligence (XAI), immersive digital twins featuring real-time 3D LiDAR capture, and AI-driven energy optimization systems focused on renewable self-consumption.
ROBOTNIK AT THE PROJECT
Within the framework of the SICODI project, Robotnik leads the consortium and drives the research, development, and integration of autonomous mobile robotics, cognitive perception, and industrial validation environments.
Robotnik’s participation is structured around three main strategic axes:
- Adaptive Cognitive Robotics and Natural Language Control: Research and implementation of Large Language Models (LLMs) and the MCP (Model Context Protocol) framework over ROS 2 middleware, enabling the command, reconfiguration, and coordination of mobile manipulator fleets through natural language instructions.
- Advanced Perception and Explainable AI (XAI): Integration of computer vision and XAI algorithms into adaptive control loops for transparent anomaly detection, diagnosis, and self-correction during operations shared with human workers. Additionally, Robotnik leads the real-time, ultra-realistic 3D environmental mapping using onboard LiDAR sensors to feed the system’s digital twin.
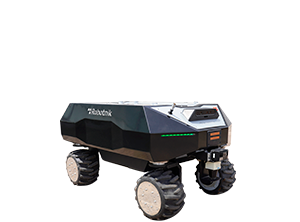
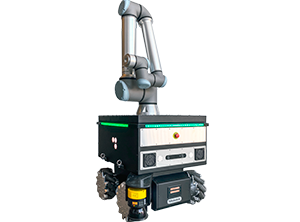
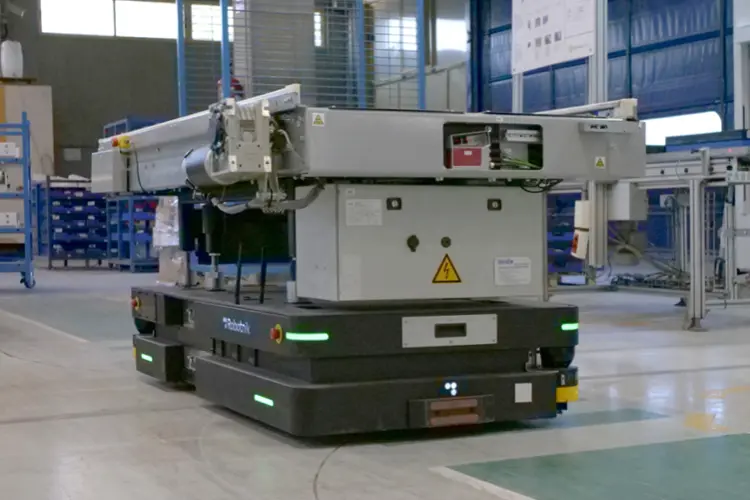
- Industrial Pilot Deployment and Validation (TRL6): Robotnik provides its industrial facilities as the primary validation testbed. A Factory 5.0 environment will be simulated in this pilot plant, integrating its mobile robotic platforms (such as RB-ROBOUT, KAIROS, and THERON) alongside the 5G/6G connectivity, Edge processing, DPP traceability, and adaptive energy management modules developed by the project partners.

Partners in the project


More projects